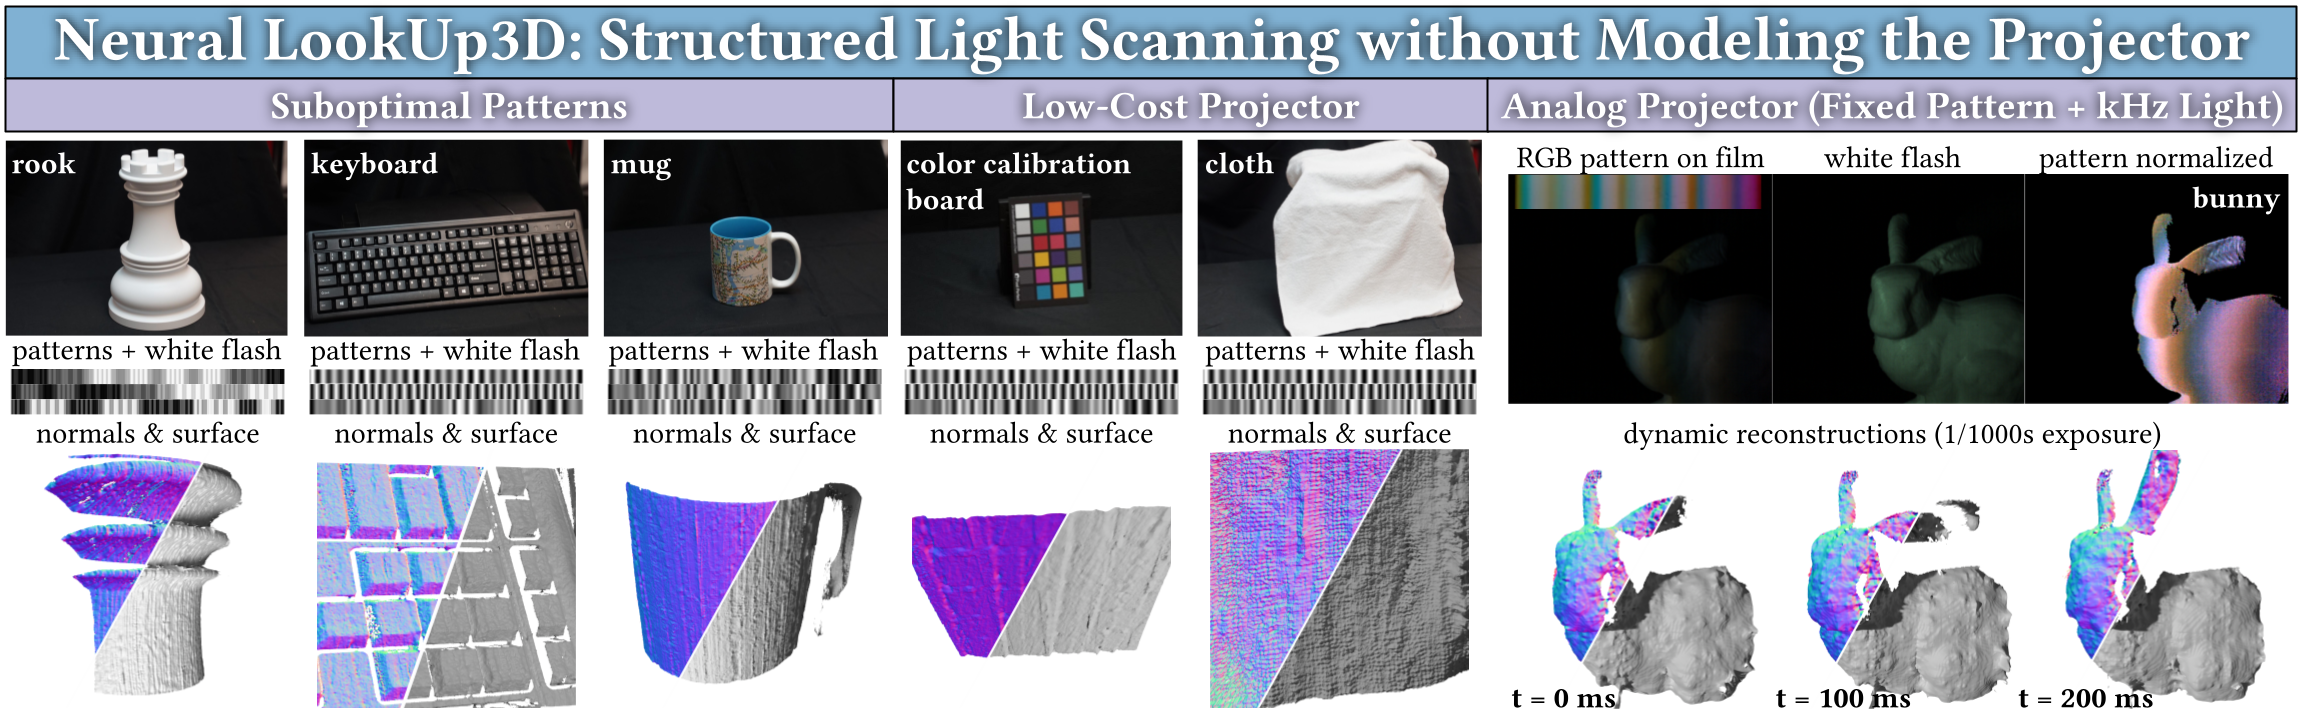
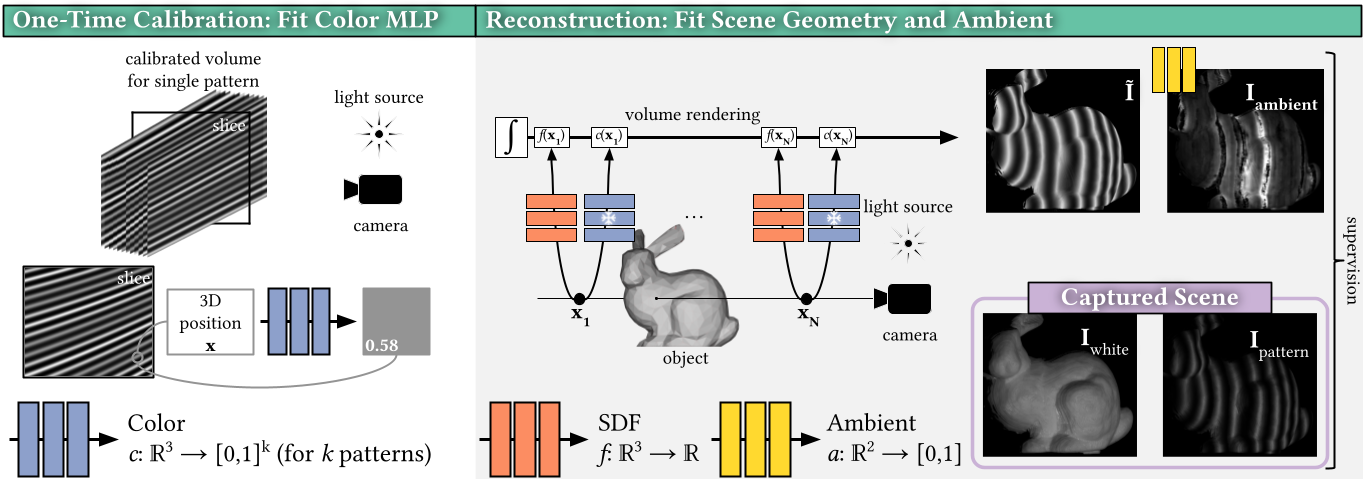
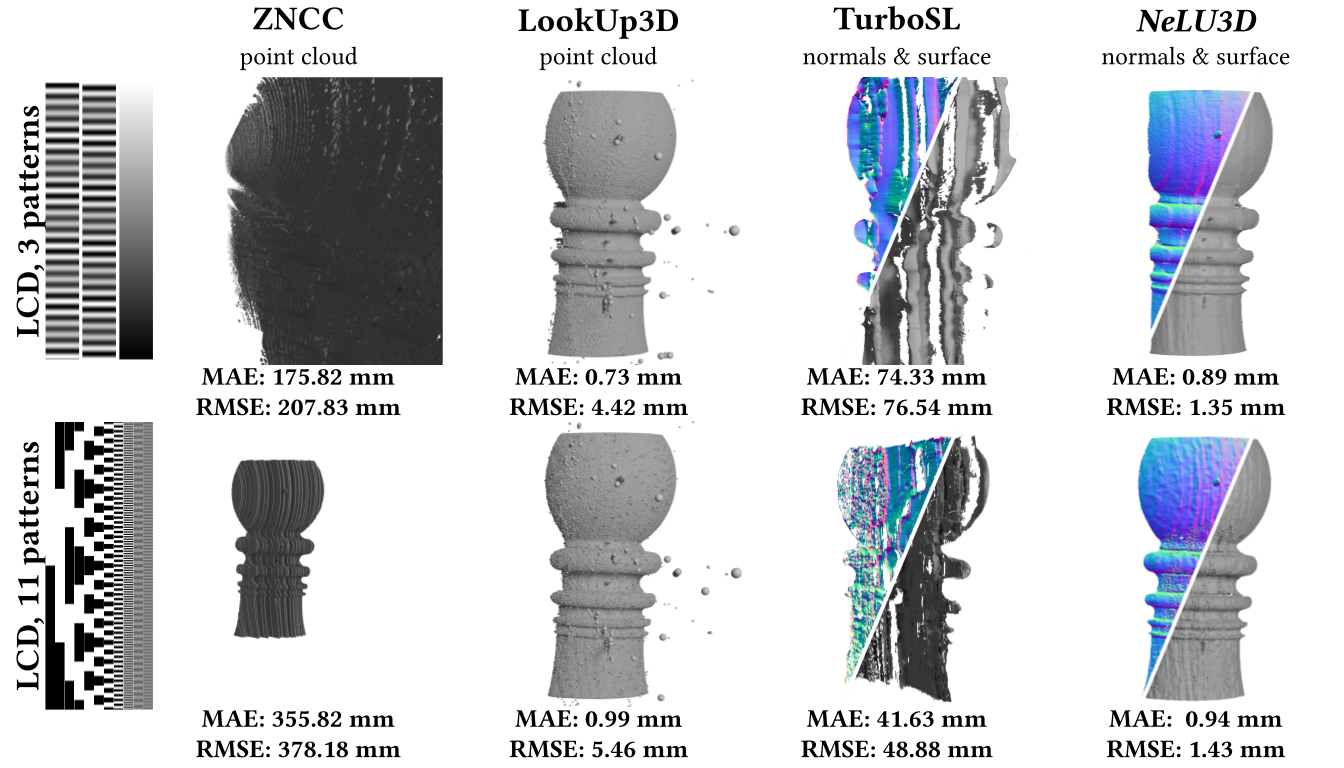
We propose NeLU3D, a neural inverse structured light (SL) method without explicitly modeling the projector. Structured Light (SL) is a popular technique that delivers precise 3D shape acquisition across diverse materials and object sizes. SL requires, however, careful modeling of the set-up, including geometric and radiometric calibration of the camera-projector pair; without it, reconstruction quality degrades. We calibrate the camera-projector system using a neural network that maps 3D positions to a set of projected patterns. Then, with as few as four monochromatic images (or two RGB images), our approach uses differentiable volume rendering to fit a surface to match SL captures. We scan over 25 objects of different shapes and reflectances to demonstrate the feasibility and quality of our method in a handful of projector-camera set-ups, including an extremely low-cost projector and an analog projector with fixed RGB pattern. We also showcase sub-millimeter accuracy with suboptimal patterns, where previous methods recover noisy 3D surfaces.
      @inproceedings{pereira2026nelu3d,
        title={NeLU3D: Neural Inverse Structured Light Without Explicitly Modeling the Projector},
        author={Pereira, Giancarlo and Fouhey, David and Silva, Claudio T and Panozzo, Daniele},
        booktitle={European Conference on Computer Vision},
        pages={565--583},
        year={2026},
        organization={Springer}
      }